Models & worlds
Robots, arms, sensors, and props ship as models (registered in the roqsim.models
entry-point group); the static environment they sit in is a world (a built-in world definition,
or a baked MJCF scene registered in roqsim.worlds). A spawn plugin references a model by short
name — e.g. spawn_robot: {model: turtlebot4} for a robot, or spawn_model: {model:
industrial_table} to place a static prop — and sim.world selects the world; see
Available plugins and Architecture & porting playbook. Props (from roqsim_assets) are ordinary models: the
same MJCF can be placed from a world YAML with spawn_model or <include>-d into a baked scene.
Asking from a shell (or a container)
The catalogs on this page are rendered at docs-build time, which is no help inside a runtime image. The same two registries answer there:
roqsim catalog models              # every model, with the ref that resolves it
roqsim catalog worlds              # every world YAML, baked scene and built-in definition
roqsim catalog models --refs       # just the refs, one per line, for piping
roqsim catalog model turtlebot4    # one model: its file, its manifest, where its meshes come from
Both print JSON, and every row carries use – the line to put in a world file or on the command
line – because “what do I type” is the question being asked. python -m roqsim.catalog models
is the same tool for a caller that has a shell in the image but not the console script, and
roqsim mcp serve exposes list_models, get_model_details
and list_worlds to an MCP client as the same three functions.
A name printed there is a name that resolves: roqsim/tests/test_catalog.py hands every ref back
to the loader. What is listed is what each package offers – its roqsim.worlds entry point –
rather than every YAML it ships: a package’s debugging worlds are deliberately unregistered and are
run by path, so a world absent from the listing is a decision rather than an omission.
Models
roqsim_aerial
Aerial-vehicle plugins and assets for roqsim (Crazyflie 2, Holybro X500 V2, quadrotor control and a PX4 SITL bridge).
|
crazyflie_2 — Bitcraze Crazyflie 2 (nano quadrotor) for MuJoCo. License: MIT (© whoenig) – |
x500 — Holybro X500 V2 class quadrotor (~2 kg, quad-X), the airframe PX4 ships as its default SITL vehicle (4001_gz_x500). |
roqsim_assets
Shared, reusable assets for roqsim scenes: surface textures (roqsim_assets:<Name>), placeable props (spawn_model), and the belt conveyor plugin + model.
|
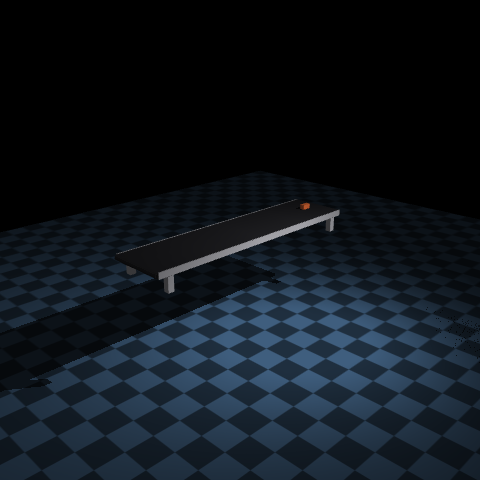
conveyor — Belt conveyor, hand-authored for roqsim. conveyor – a benchtop velocity-driven belt conveyor (invisible belt box on a slide joint, driven by |
|
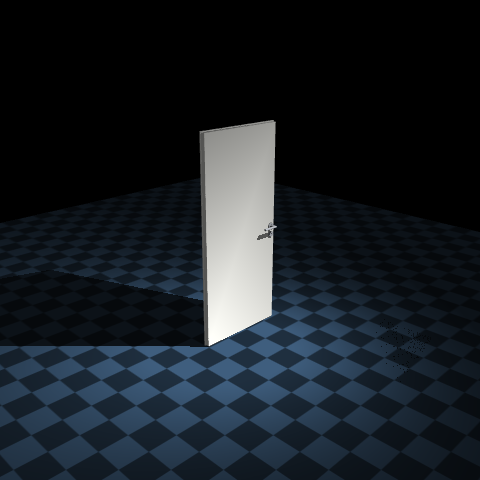
door — A single door LEAF (white panel + chrome handle) extracted from the Sketchfab “white and black wooden door low poly” unit (CC-BY oobexr; see CREDITS.txt). “WHITE AND BLACK WOODEN DOOR LOW POLY” by oobexr (https://sketchfab.com/oobexr) |
|
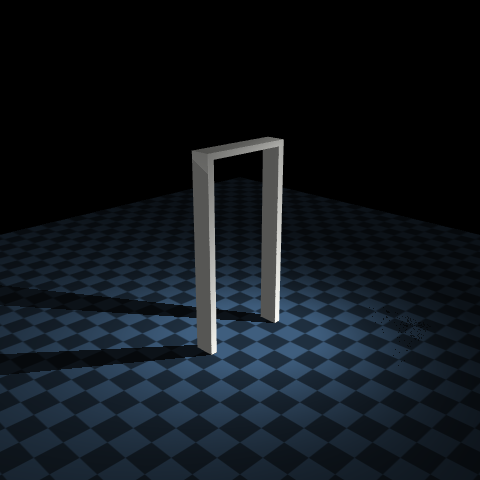
door_frame — The door FRAME (jamb + lintel casing) extracted from the Sketchfab door unit (CC-BY oobexr, see CREDITS.txt). “WHITE AND BLACK WOODEN DOOR LOW POLY” by oobexr (https://sketchfab.com/oobexr) |
|
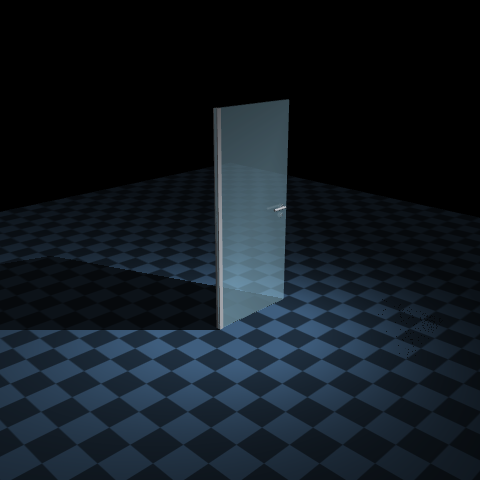
door_glass — A glass door leaf: a single uniform translucent pane (no stile/border, so it reads as glass, not a paneled door skinned in glass), a chrome hinge rail down the hinge edge that connects the pane to the frame, and the chrome handle on the latch side. “WHITE AND BLACK WOODEN DOOR LOW POLY” by oobexr (https://sketchfab.com/oobexr) |
|
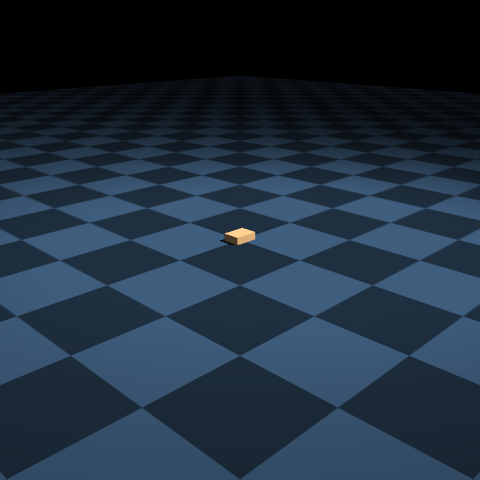
graspable_box — A small parcel sized and tuned to be picked up by a parallel gripper. graspable_box – a small parcel sized and tuned to be picked up by a parallel gripper. |
|
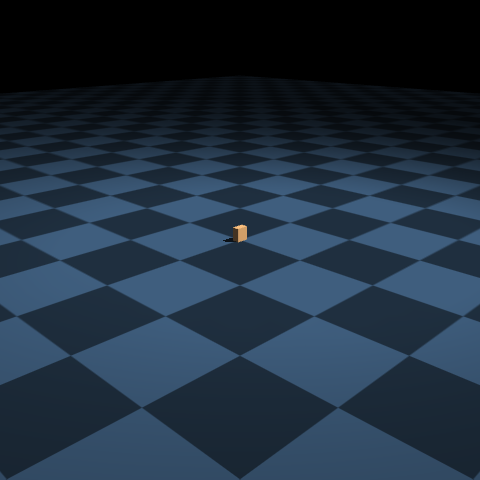
graspable_carton — A small upright carton, sized to be picked off a TABLE by a NARROW parallel gripper. graspable_carton – a small upright carton, sized to be picked off a table by a narrow parallel |
|
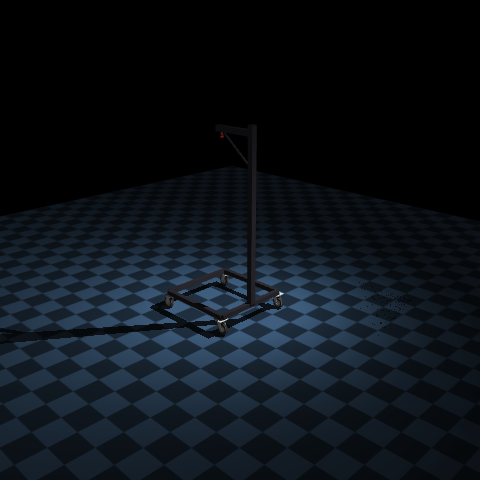
humanoid_gantry — Mobile suspension gantry for hanging a small humanoid (Unitree G1 ~1.3 m, LimX Oli ~1.45 m) clear of the floor for bring-up/policy testing. humanoid_gantry – mobile suspension gantry for hanging a small humanoid (G1 / Oli). |
|
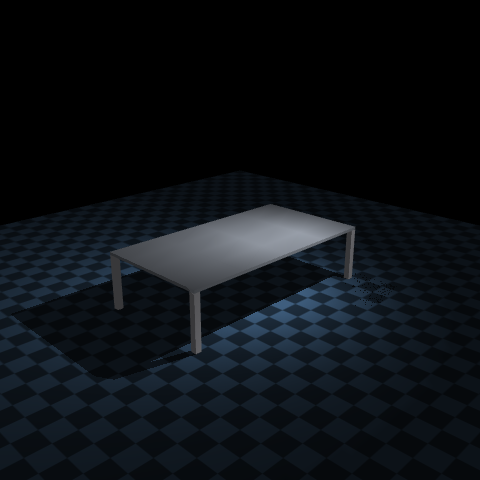
industrial_table — Heavy industrial workbench: a 2.90 x 1.56 m top at z=0.76 on four 0.08 x 0.08 m legs. industrial_table – a heavy industrial workbench (2.90 x 1.56 m top at z=0.76 on four legs), split |
|
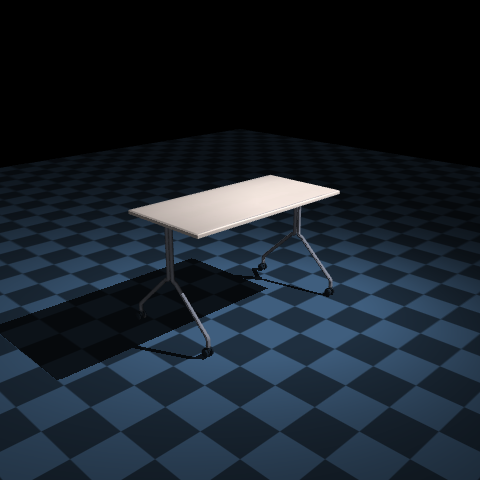
office_table — Trestle office desk, 1.20 x 0.60 m top at z=0.68..0.72, carried by two A-frames at x = +-0.55. “Office_Table” by Art_bravado (https://sketchfab.com/Art_bravado) |
|
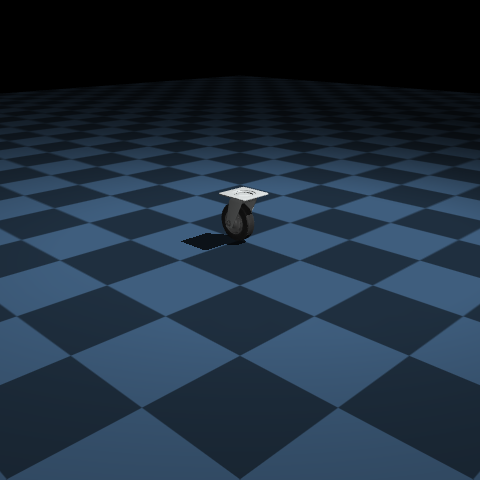
trolley_wheel — Heavy-duty swivel trolley caster (wheel + top mounting bracket). “Hard Surface Study (Trolley Wheel)” by WizBeatrix (https://sketchfab.com/WizBeatrix) |
roqsim_humanoid
Humanoid plugins and assets for roqsim (Unitree G1 + LimX Oli + RL locomotion).
|
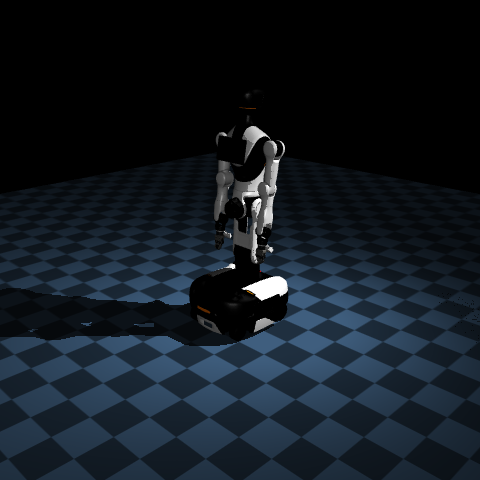
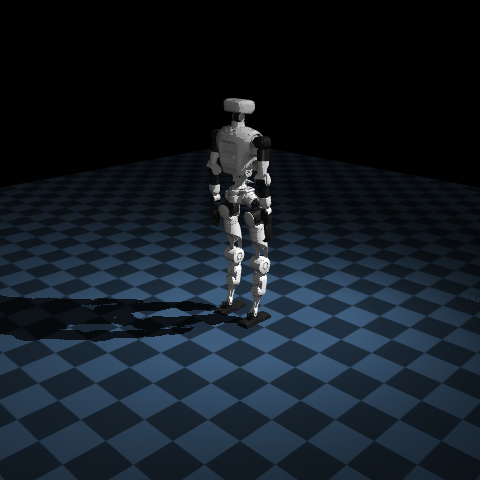
agibot_g2 — AgiBot G2 (wheeled dual-arm mobile manipulator) for MuJoCo. License: MPL-2.0 – |
|
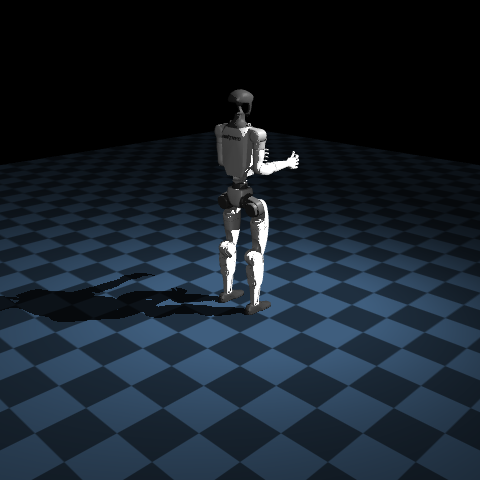
oli — LimX Oli (HU_D04_01) humanoid for MuJoCo, in the serial PR-space form the vendor walk policy expects. License: Apache-2.0 – |
|
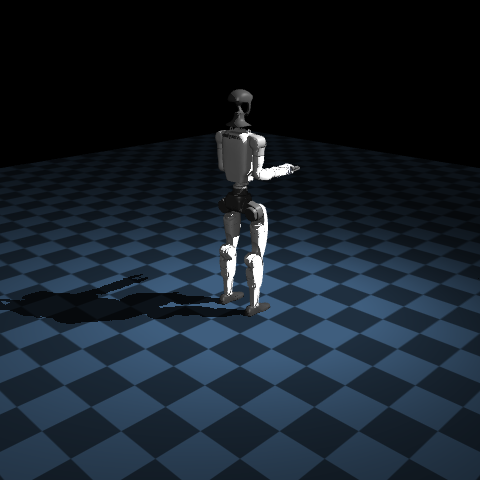
unitree_g1 — Unitree G1, 12-DoF leg-only walking model. License: BSD-3-Clause (© HangZhou YuShu TECHNOLOGY CO.,LTD. (“Unitree Robotics”)) – |
|
unitree_g1_dex1 — Unitree G1, 29-DoF manipulation variant: the 12-DoF walking legs plus waist, arms and a Dex1 parallel gripper per side. License: BSD-3-Clause (© HangZhou YuShu TECHNOLOGY CO.,LTD. (“Unitree Robotics”)) – |
roqsim_manipulation_assets
Manipulator ASSETS for roqsim: arm and gripper models plus their meshes (UR10e, UR5e, Franka Panda, Kinova Gen3, OpenManipulator-X, Robotiq 2F-85, Schunk PG+70). Real robots only – workpieces ship with the experiments that define them.
|
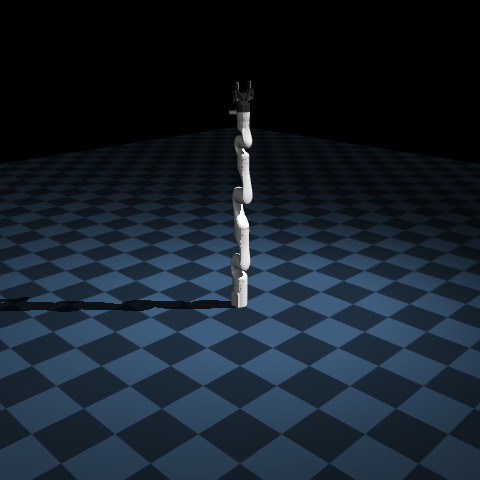
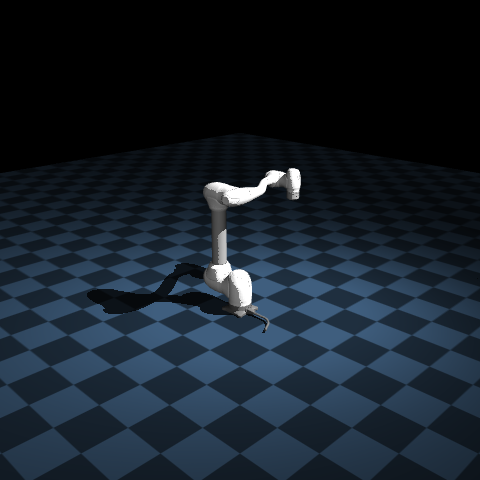
gen3 — Kinova Gen3 (7-DOF) + Robotiq 2F-85 parallel gripper, assembled for roqsim from two MuJoCo Menagerie models (kinova_gen3, robotiq_2f85; see GEN3_LICENSE / ROBOTIQ_2F85_LICENSE). License: BSD-3-Clause (© Kinova inc.) – |
|
m1013 — Doosan M1013 (6-axis collaborative arm) for MuJoCo. License: Apache-2.0 (© Doosan Robotics) – |
|
open_manipulator_x — ROBOTIS OpenMANIPULATOR-X (4-joint serial arm + parallel gripper) for MuJoCo. License: Apache-2.0 – |
|
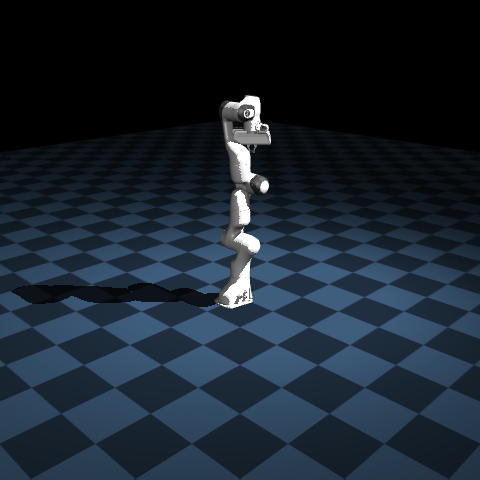
panda — Franka Emika Panda (7-DoF arm + Franka Hand parallel gripper) for MuJoCo. License: Apache-2.0 – |
|
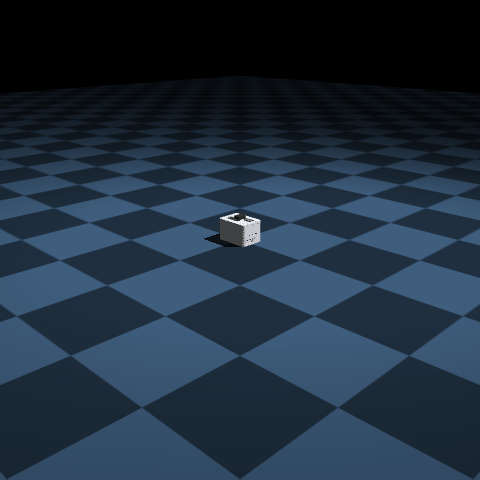
robotiq_2f85 — Robotiq 2F-85 parallel gripper, standalone and attachable to ANY arm flange. License: BSD-3-Clause (© ROS-Industrial) – |
|
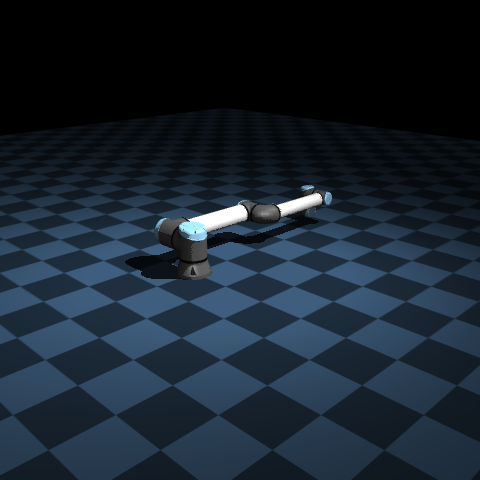
schunk_pg70 — Schunk PG+70 two-finger parallel gripper, standalone and attachable to any arm flange. License: Apache-2.0 (© Pilz GmbH & Co. KG) – |
|
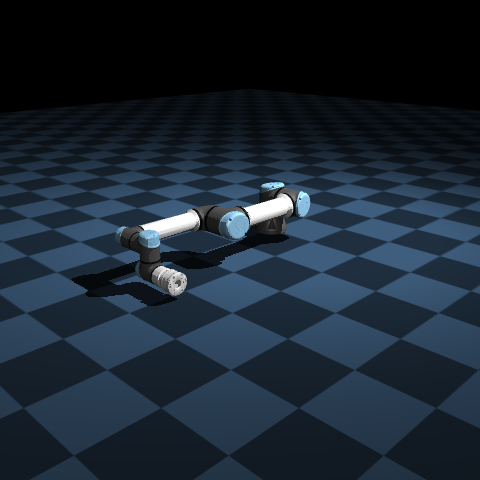
ur10e — Universal Robots UR10e (6-DoF collaborative arm) for MuJoCo. License: BSD-3-Clause (© ROS Industrial Consortium) – |
|
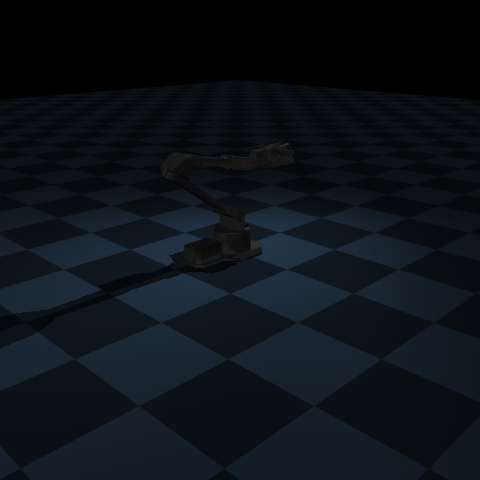
ur5e — Universal Robots UR5e (6-DoF collaborative arm) for MuJoCo. License: BSD-3-Clause (© ROS Industrial Consortium) – |
|
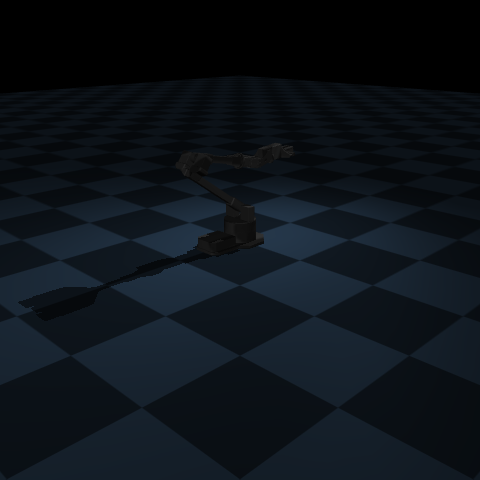
vx300s — Interbotix/Trossen ViperX 300 6DOF (vx300s) for MuJoCo. License: BSD-3-Clause (© Trossen Robotics) – |
|
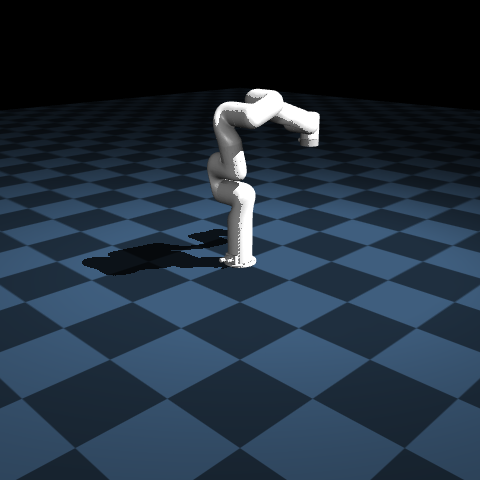
wx250s — Interbotix/Trossen WidowX 250 6DOF (wx250s) for MuJoCo. License: BSD-3-Clause (© Trossen Robotics) – |
|
xarm7 — UFACTORY xArm 7 (7-DoF serial arm) for MuJoCo. License: BSD-3-Clause (© UFACTORY Inc.) – |
roqsim_mobile
Wheeled-base plugins and models for roqsim (floorplan, diff-drive, omni-drive).
|
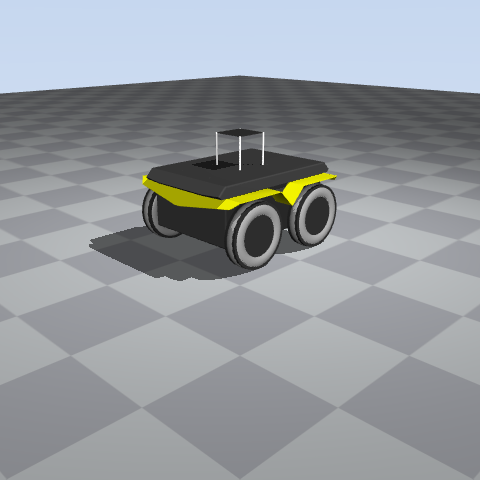
clearpath_jackal — Clearpath Jackal (J100, 4-wheel skid-steer) for MuJoCo. License: BSD-3-Clause (© Clearpath Robotics Inc.) – |
|
create3_dock — The iRobot Create 3 charging dock (irobot_create_description/urdf/dock/standard_dock.urdf.xacro @ 1fccb76), the prop a TurtleBot 4 docks to. License: BSD-3-Clause (© iRobot Corporation.) – |
|
floor — Scene floor: a checker ground plane plus its material, kept regardless of the chosen environment. |
|
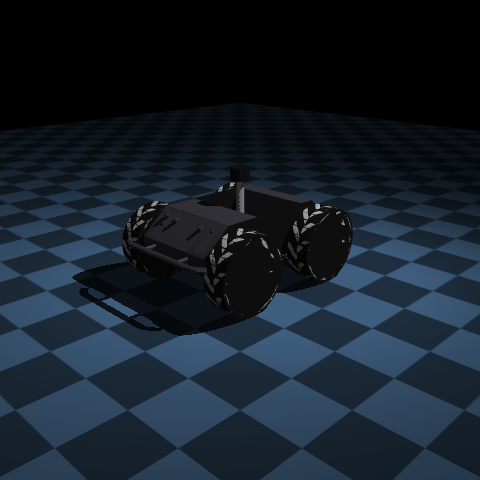
husky_a200 — Clearpath Husky A200 (skid-steer) for MuJoCo. License: BSD-3-Clause (© Clearpath Robotics, Inc.) – |
|
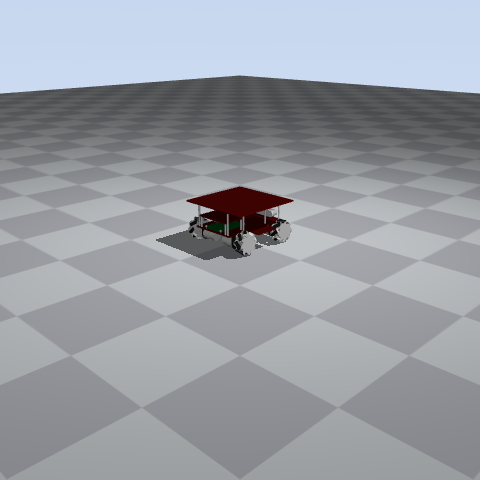
lgdxrobot2 — LGDXRobot2 - a 0.24 m four-wheel mecanum research platform, 2.68 kg. License: MIT (© Kai Tung Yu) – |
|
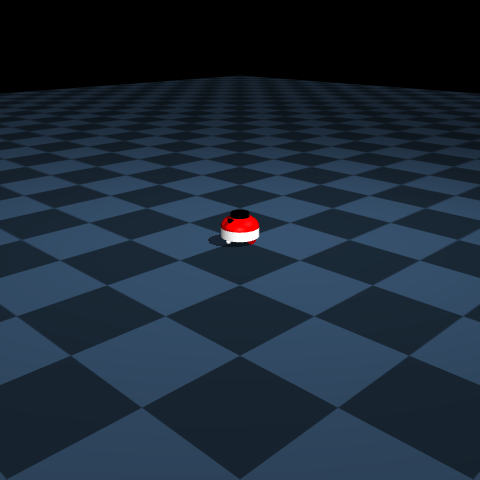
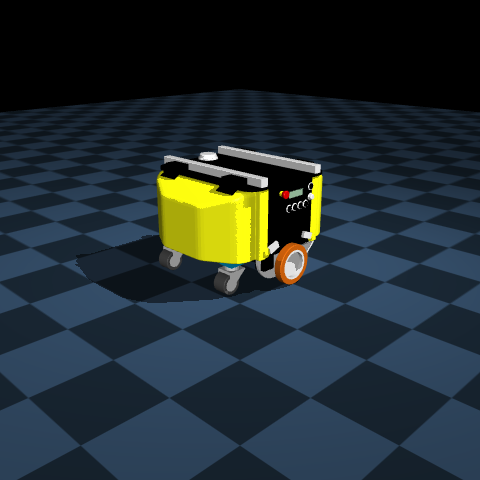
makerspet_mini — Maker’s Pet Mini - a 3D-printed differential-drive pet robot with a 2D lidar. License: Apache-2.0 (© Ilia O.) – |
|
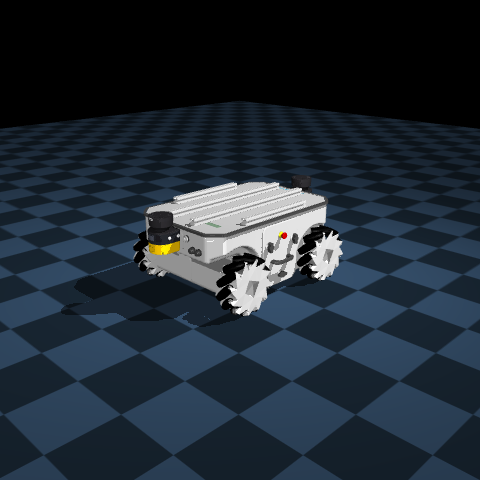
mp_400 — Neobotix MP-400 - a DIFFERENTIAL-drive base: two driven wheels, four passive casters. License: MIT (© neobotix gmbh) – |
|
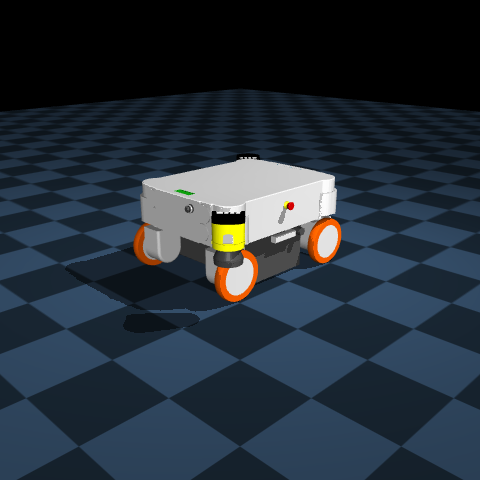
mpo_500 — Neobotix MPO-500 - a four-wheel OMNIDIRECTIONAL base, 72.8 kg. License: MIT (© neobotix gmbh) – |
|
mpo_700 — Neobotix MPO-700 - a four-wheel SWERVE (independently steered) omnidirectional base, 196.8 kg. License: MIT (© neobotix gmbh) – |
|
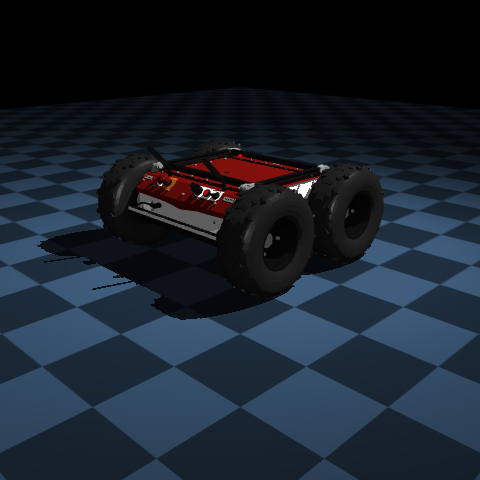
oomwoo_one — OOMWOO One open-source robot vacuum (2-wheel differential drive + caster) for MuJoCo. License: Apache-2.0 (© Ilia O.) – |
|
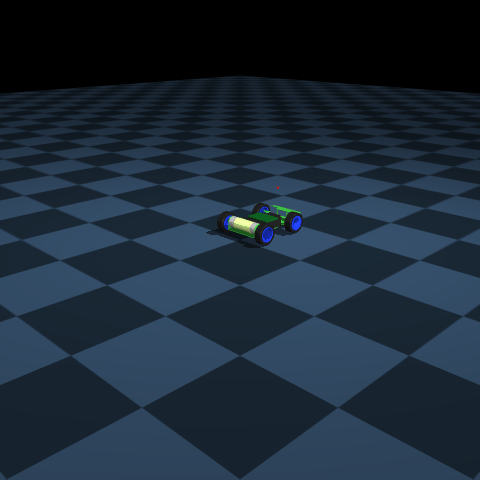
panther — Husarion Panther (4-wheel skid-steer UGV) for MuJoCo, WH01 wheels. License: Apache-2.0 (© Husarion) – |
|
piracer — Waveshare PiRacer - a 0.236 m Ackermann-steered RC car, and the first car-like base here. License: MIT (© Sujong Ha) – |
|
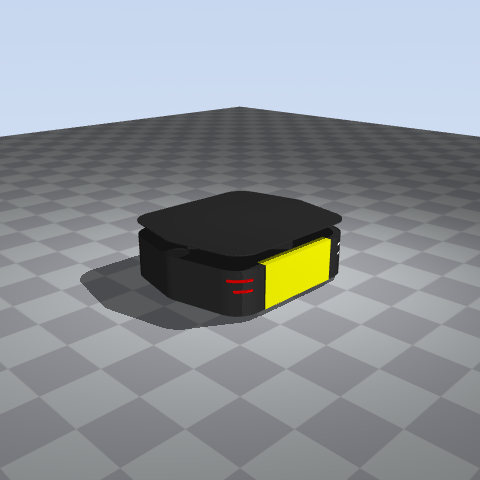
raspimouse — RT Corporation Raspberry Pi Mouse (2-wheel differential drive) for MuJoCo. License: MIT (© RT Corporation) – |
|
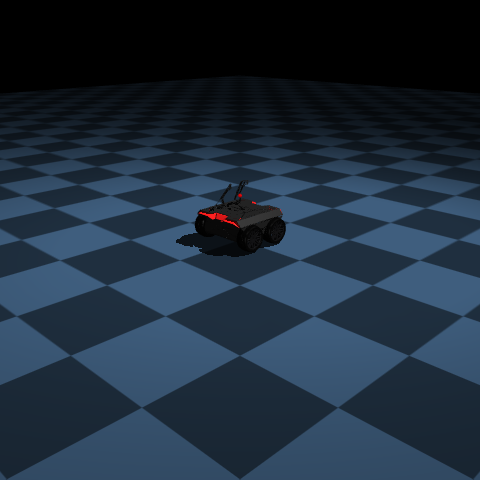
ridgeback — Clearpath Ridgeback (4-wheel mecanum, holonomic) for MuJoCo. License: BSD-3-Clause (© clearpathrobotics) – |
|
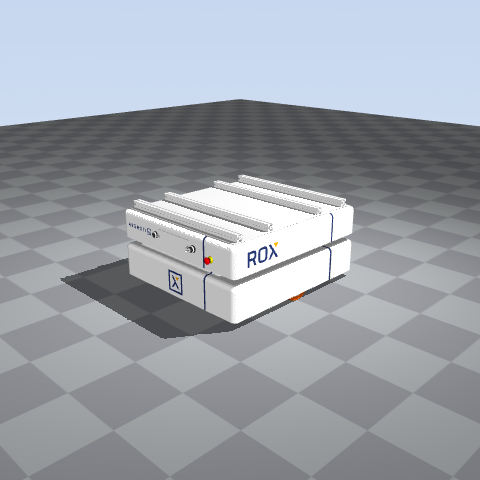
rosbot — Husarion ROSbot (4-wheel skid-steer) for MuJoCo. License: Apache-2.0 (© Husarion) – |
|
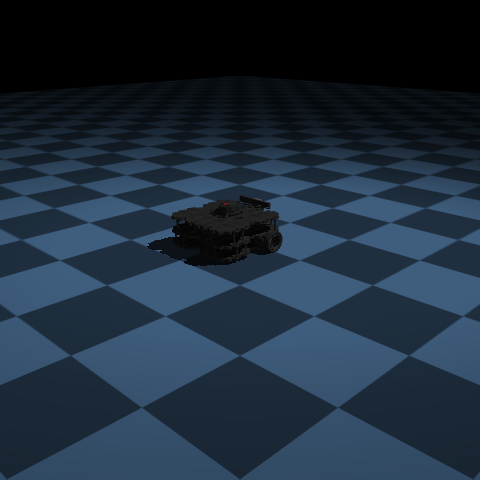
rox_diff — Neobotix ROX-Diff - a DIFFERENTIAL-drive base: two driven wheels on the centre line, four passive casters. License: see |
|
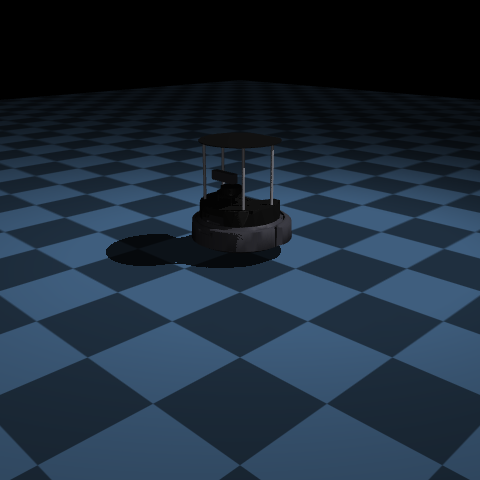
turtlebot3_waffle — ROBOTIS TurtleBot3 Waffle (differential drive) for MuJoCo. License: Apache-2.0 – |
|
turtlebot4 — TurtleBot 4 (standard) for MuJoCo. License: Apache-2.0 – |
|
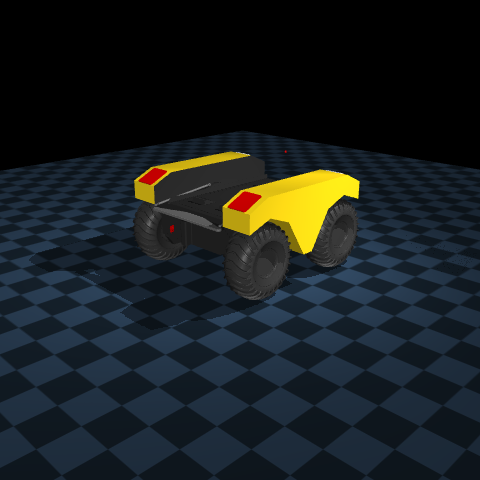
warthog — Clearpath Warthog W200 (4-wheel outdoor skid-steer) for MuJoCo. License: BSD-3-Clause (© clearpathrobotics) – |
roqsim_mobile_manipulation
Mobile-manipulator robot models for roqsim: composite platforms that are a mobile base plus an arm (Panda-on-Omron-LD-60 ‘Frankie’, PAL TIAGo Pro).
|
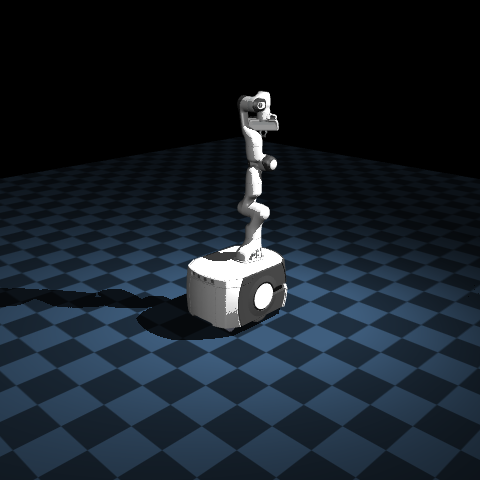
frankie — Frankie - a Franka Emika Panda on an Omron LD-60 differential-drive base - for MuJoCo. Borrows assets from: License: MIT (© jhavl) – |
|
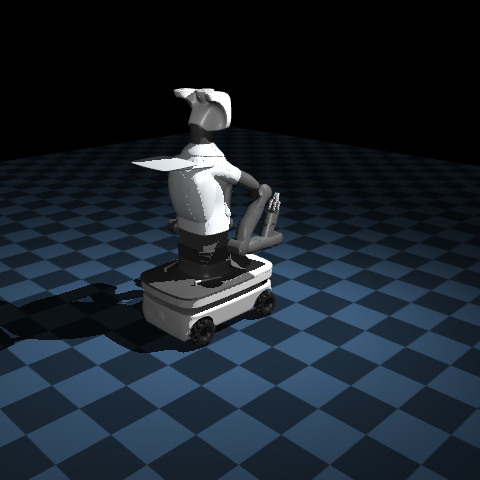
tiago_pro — PAL Robotics TIAGo Pro (omnidirectional base, SEA arm, head and PRO gripper) for MuJoCo. License: Apache-2.0 (© PAL Robotics S.L.) – |
roqsim_quadruped
Quadruped plugins and assets for roqsim (Boston Dynamics Spot + RL locomotion controller).
|
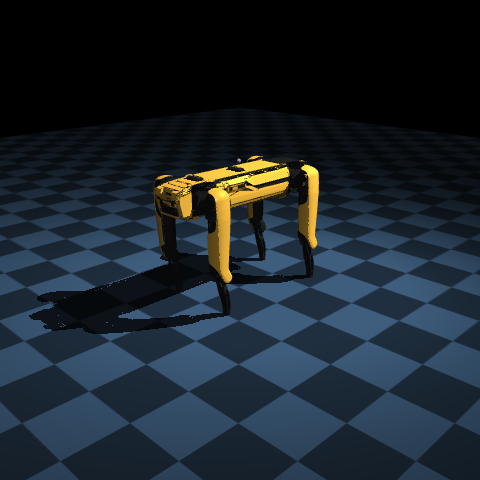
spot — Boston Dynamics Spot, 12-DoF quadruped walking model. License: BSD-3-Clause (© Clearpath Robotics Inc.) – |
roqsim_sensors
Generic (robot-family-agnostic) sensor plugins for roqsim (2D lidar, Livox Mid-360 3D lidar, Seyond Robin W1G solid-state lidar, OAK-D, RealSense D435/D415/D455, Zivid 3 XL250).
|
d415 — Intel RealSense D415: visual mesh + a colour camera, for a standalone mount (see the spawn_sensor plugin) or as an eye-in-hand camera on a robot. License: Apache-2.0 (© RealSense, Inc.) – |
|
d435 — Intel RealSense D435: visual mesh + a colour camera, for a standalone mount (see the spawn_sensor plugin) – not attached to any robot’s own MJCF. License: Apache-2.0 (© RealSense, Inc.) – |
|
d455 — Intel RealSense D455: visual mesh + a colour camera, for a standalone mount (see the spawn_sensor plugin) or as an eye-in-hand camera on a robot. License: Apache-2.0 (© RealSense, Inc.) – |
|
hokuyo_ust — Hokuyo UST-10LX 2D lidar: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: BSD-3-Clause (© clearpathrobotics) – |
|
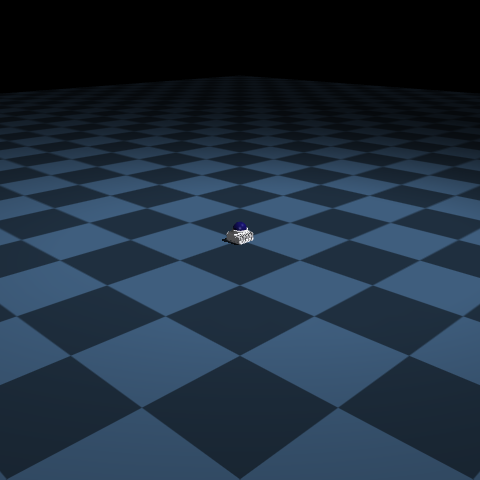
lds01 — ROBOTIS LDS-01 (HLS-LFCD2) 2D lidar: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: Apache-2.0 (© ROBOTIS CO., LTD.) – |
|
mid360 — Livox Mid-360 3D lidar: a standalone mount (primitive housing + a mid360 scan site) for the spawn_sensor plugin, mounted on its own or by a robot manifest at the vendor joint origin. License: see |
|
oakd — Luxonis OAK-D Pro: a box stand-in + a colour camera, for a standalone mount (see the spawn_sensor plugin) – not attached to any robot’s own MJCF. License: Apache-2.0 (© Open Navigation LLC) – |
omron_os32c — Omron OS32C safety laser scanner: a standalone mount (primitive housing + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its mounting face. License: see |
|
|
robin_w1g — Seyond Robin W1G solid-state 3D lidar: a standalone mount (visual mesh + a robin_w1g scan site) for the spawn_sensor plugin – not attached to any robot’s own MJCF. License: see |
|
rplidar_a1 — Slamtec RPLIDAR A1 (A1M8) 2D lidar: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: Apache-2.0 (© Clearpath Robotics, Inc.) – |
|
rplidar_c1 — Slamtec RPLIDAR C1 2D lidar: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: Apache-2.0 (© Husarion sp. z o.o.) – |
rplidar_s3 — Slamtec RPLIDAR S3 2D lidar: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: Apache-2.0 (© Husarion sp. z o.o.) – |
|
|
sick_lms1xx — SICK LMS111 2D lidar: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: BSD-3-Clause (© clearpathrobotics) – |
|
sick_microscan3 — SICK microScan3 Core safety laser scanner: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: MIT (© neobotix gmbh) – |
|
sick_nanoscan3 — SICK nanoScan3 safety laser scanner: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: see |
|
sick_s300 — SICK S300 safety laser scanner: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: MIT (© neobotix gmbh) – |
|
sick_tim571 — SICK TiM571 2D lidar: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: Apache-2.0 (© PAL Robotics S.L.) – |
|
velodyne_vlp16 — Velodyne VLP-16 (Puck) lidar: a standalone mount (housing mesh + a scan site) for the spawn_sensor plugin, mounted by a robot manifest at its vendor joint origin. License: BSD-3-Clause (© Dataspeed Inc.) – |
|
zivid — Zivid 3 XL250 industrial structured-light 3D camera: a standalone mount (visual mesh + a colour camera + a zivid optical site) for the spawn_sensor plugin – not attached to any robot’s own MJCF. License: see |
roqsim_walker
Kinematic pedestrian walkers for roqsim: a skinned humanoid on mocap bodies, navigated by roqsim_nav.
|
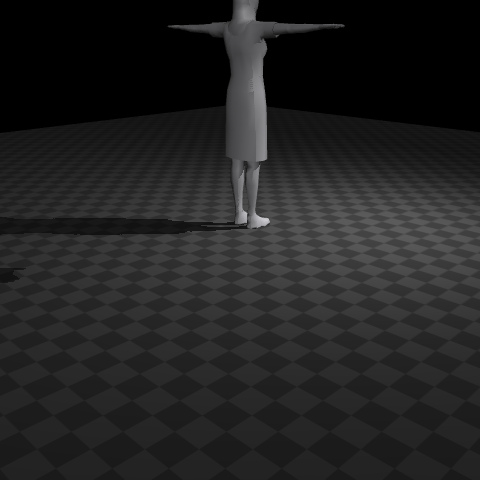
FemaleVisitorWalk — Procedural skinned pedestrian blueprint (no MJCF; body + skin generated at build time). |
|
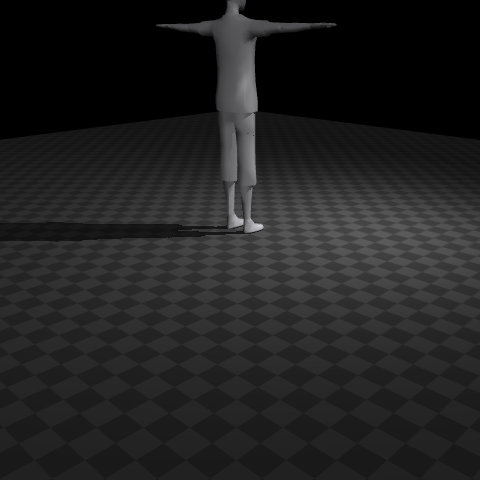
MaleVisitorWalk — Procedural skinned pedestrian blueprint (no MJCF; body + skin generated at build time). |
Worlds
Built-in world definitions
empty_room — built-in world definition Ground plane + ceiling light, enclosed by four perimeter walls. Selected with |
roqsim_scenes
|
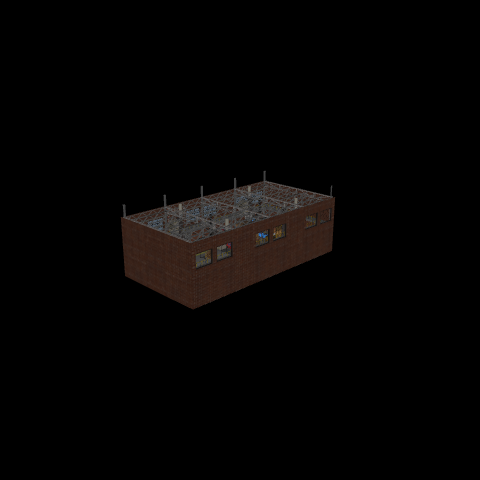
depot — MuJoCo scene worlds imported from CAD, USD or Gazebo SDF, baked to plain MJCF. Baked MJCF scene. Reference as |
|
tb3_world — MuJoCo scene worlds imported from CAD, USD or Gazebo SDF, baked to plain MJCF. Baked MJCF scene. Reference as |